Engineering Science · University of Toronto

Hi, I'm Paul

I enjoy building robots that see, think, and act.

Third-year Engineering Science student (Robotics Major, AI Minor) with hands-on experience spanning vision-based manipulation, closed-loop control, simulation, and reinforcement learning. I bring strong problem-solving skills, attention to technical detail, and a collaborative mindset to every team I join.

Paul Choi

About Me

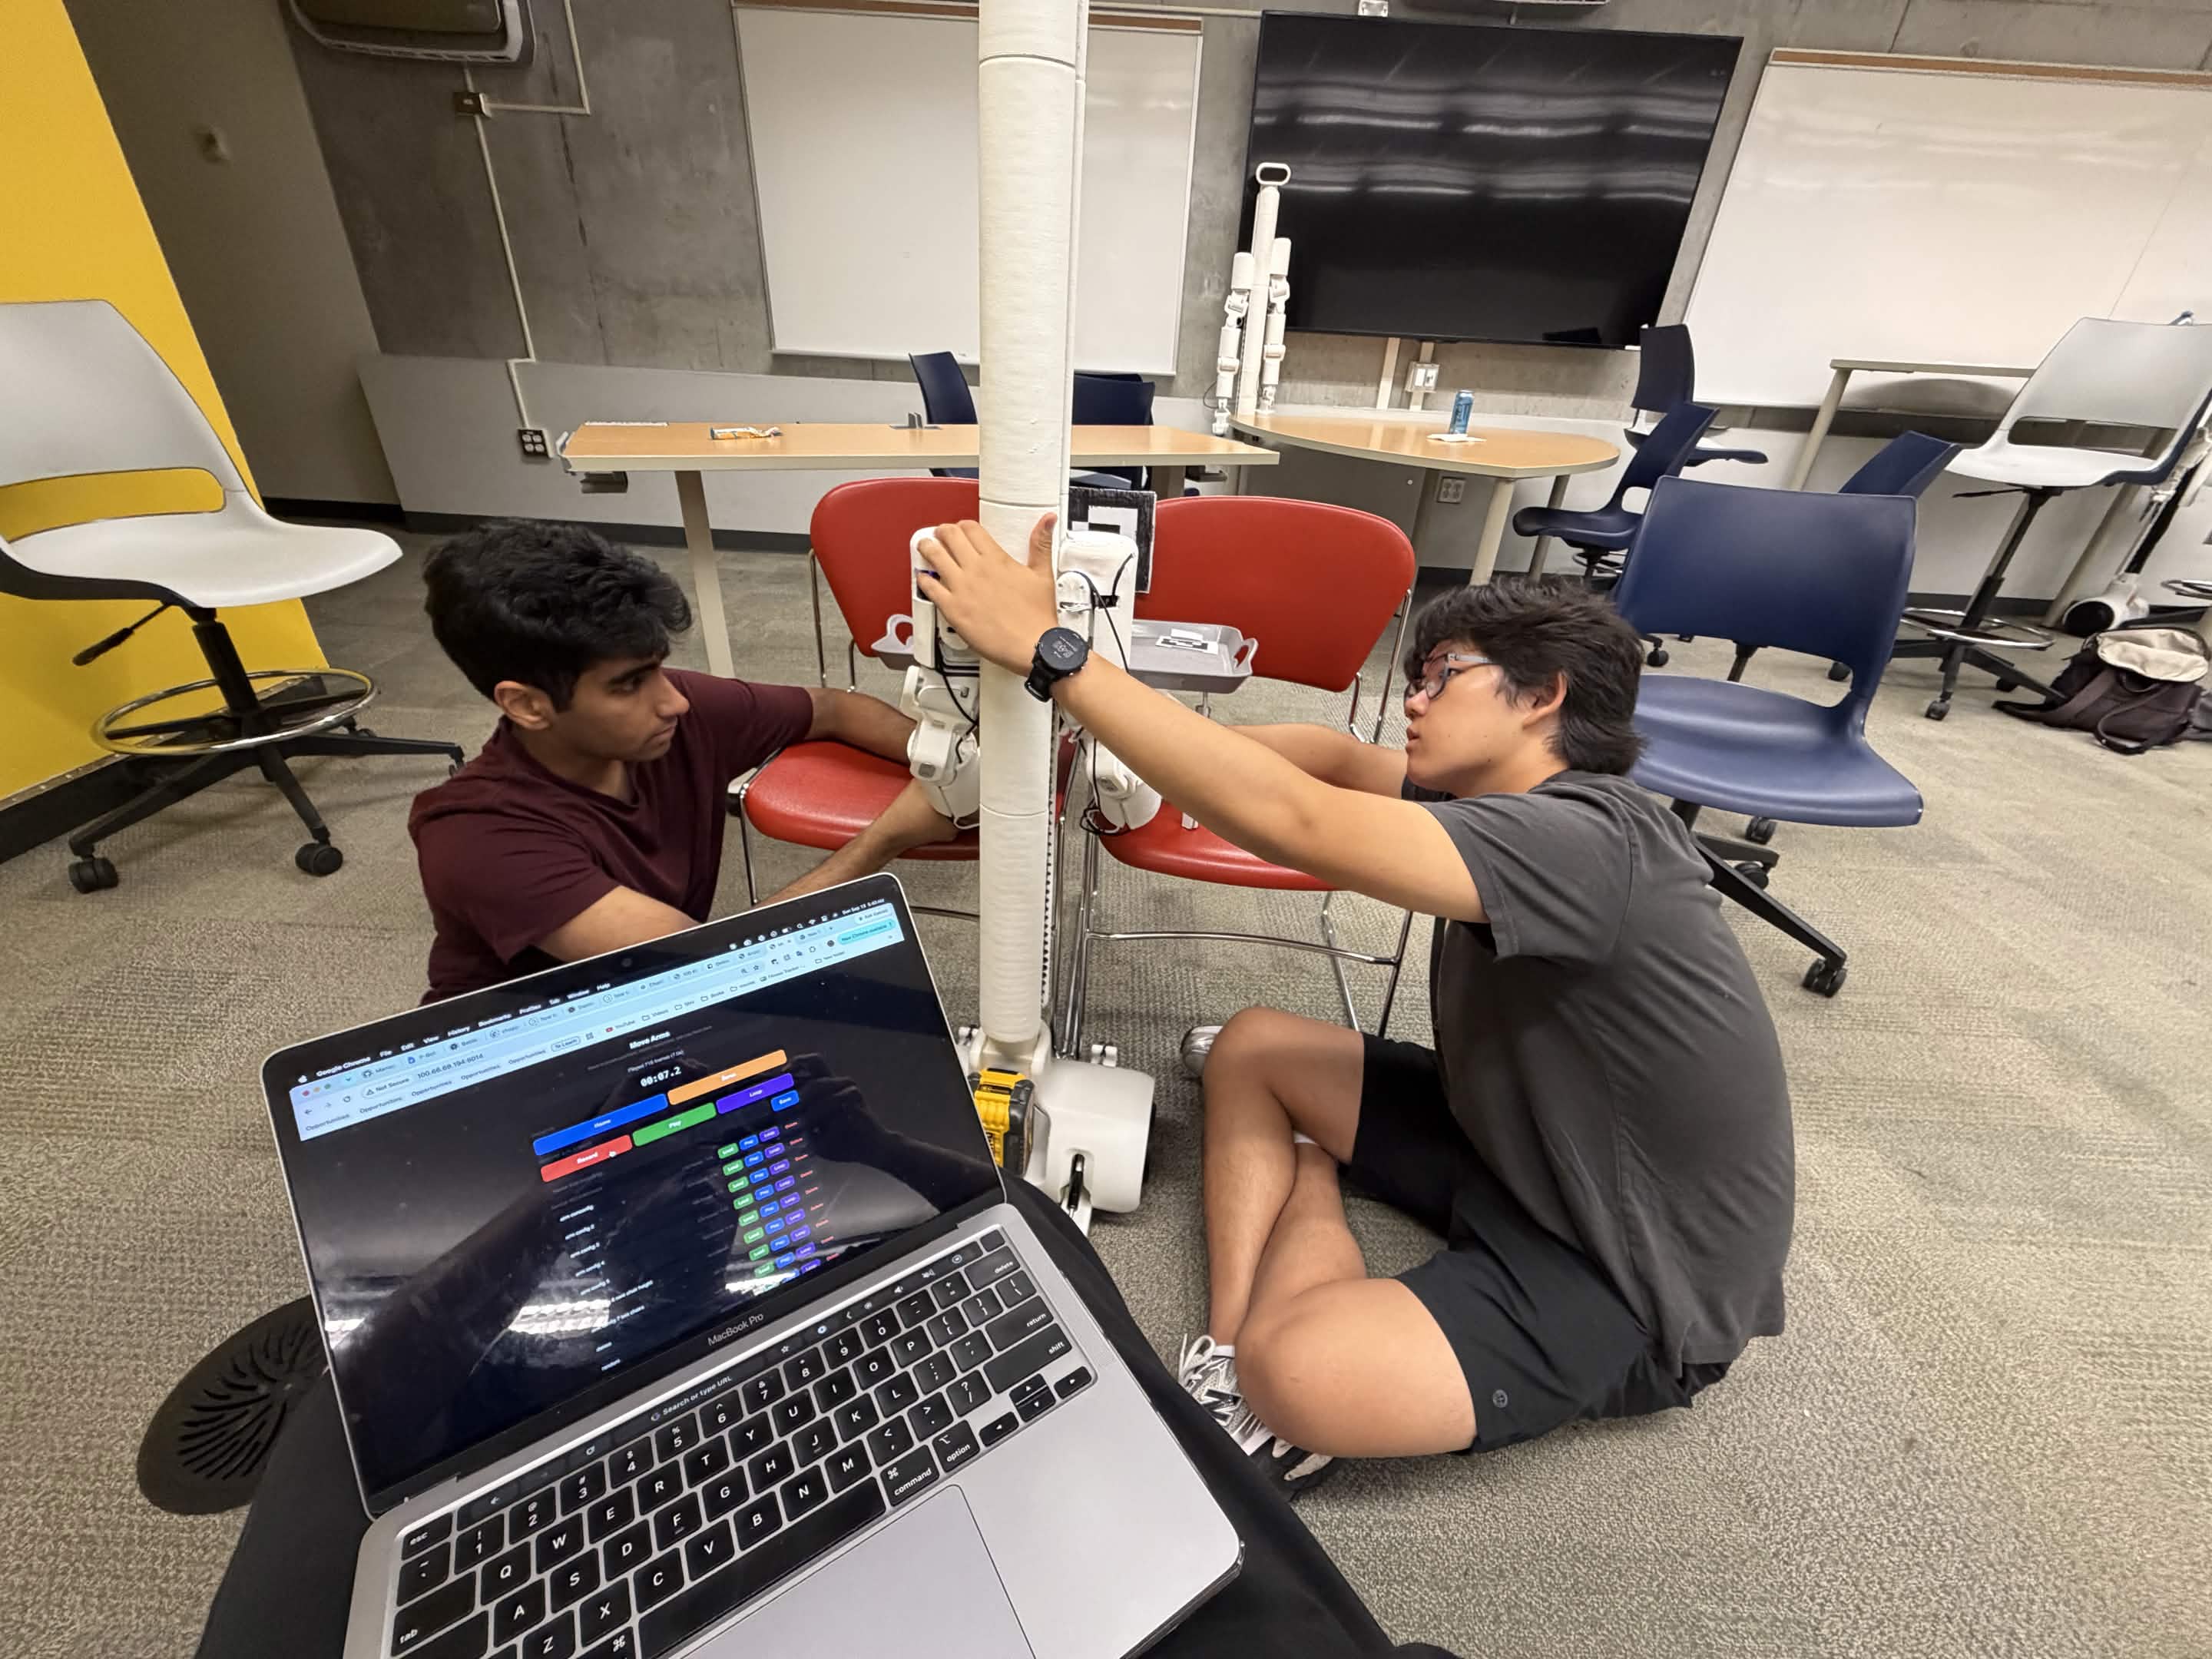
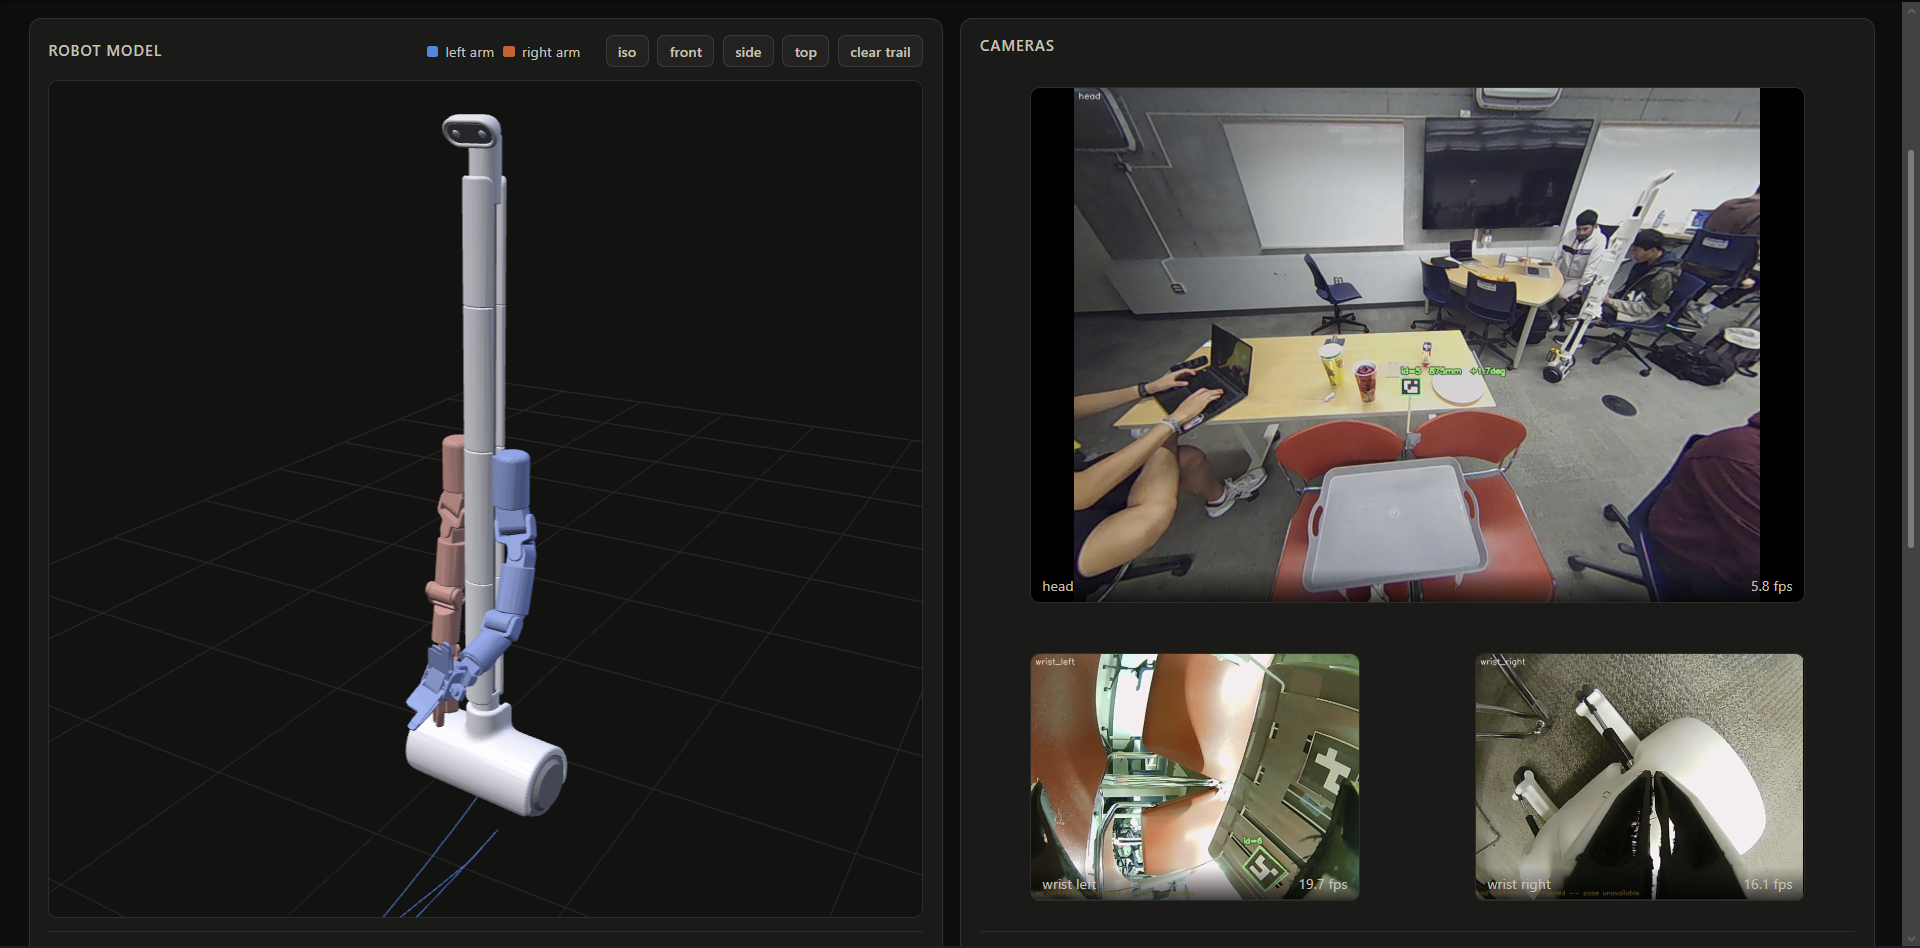
I'm a third-year Engineering Science student at the University of Toronto, majoring in Robotics Engineering with a minor in Artificial Intelligence. I like taking a robot from a rough idea to a working system: designing the mechanism in CAD, modeling it in simulation, writing the control and perception stack, and getting it running on real hardware.

My work spans the full robotics stack: mechanical design in Fusion 360, embedded and low-level control, camera calibration and computer vision, simulation in Isaac Sim and MuJoCo, and reinforcement learning with PyTorch. Beyond personal projects, I work on autonomous mapping and localization and, more recently, PCB design in Altium, power, and firmware architecture on the electrical team for the University of Toronto Formula Racing driverless car, and I volunteer repairing clinical equipment at St. Michael's Hospital.

I'm at my best on open-ended engineering problems: I can work independently, break down ambiguity into concrete next steps, and pay close attention to quality and technical detail. I communicate clearly and enjoy collaborating with cross-functional teams, from mechanical and electrical to software, across different sites and disciplines.

Selected work

Projects

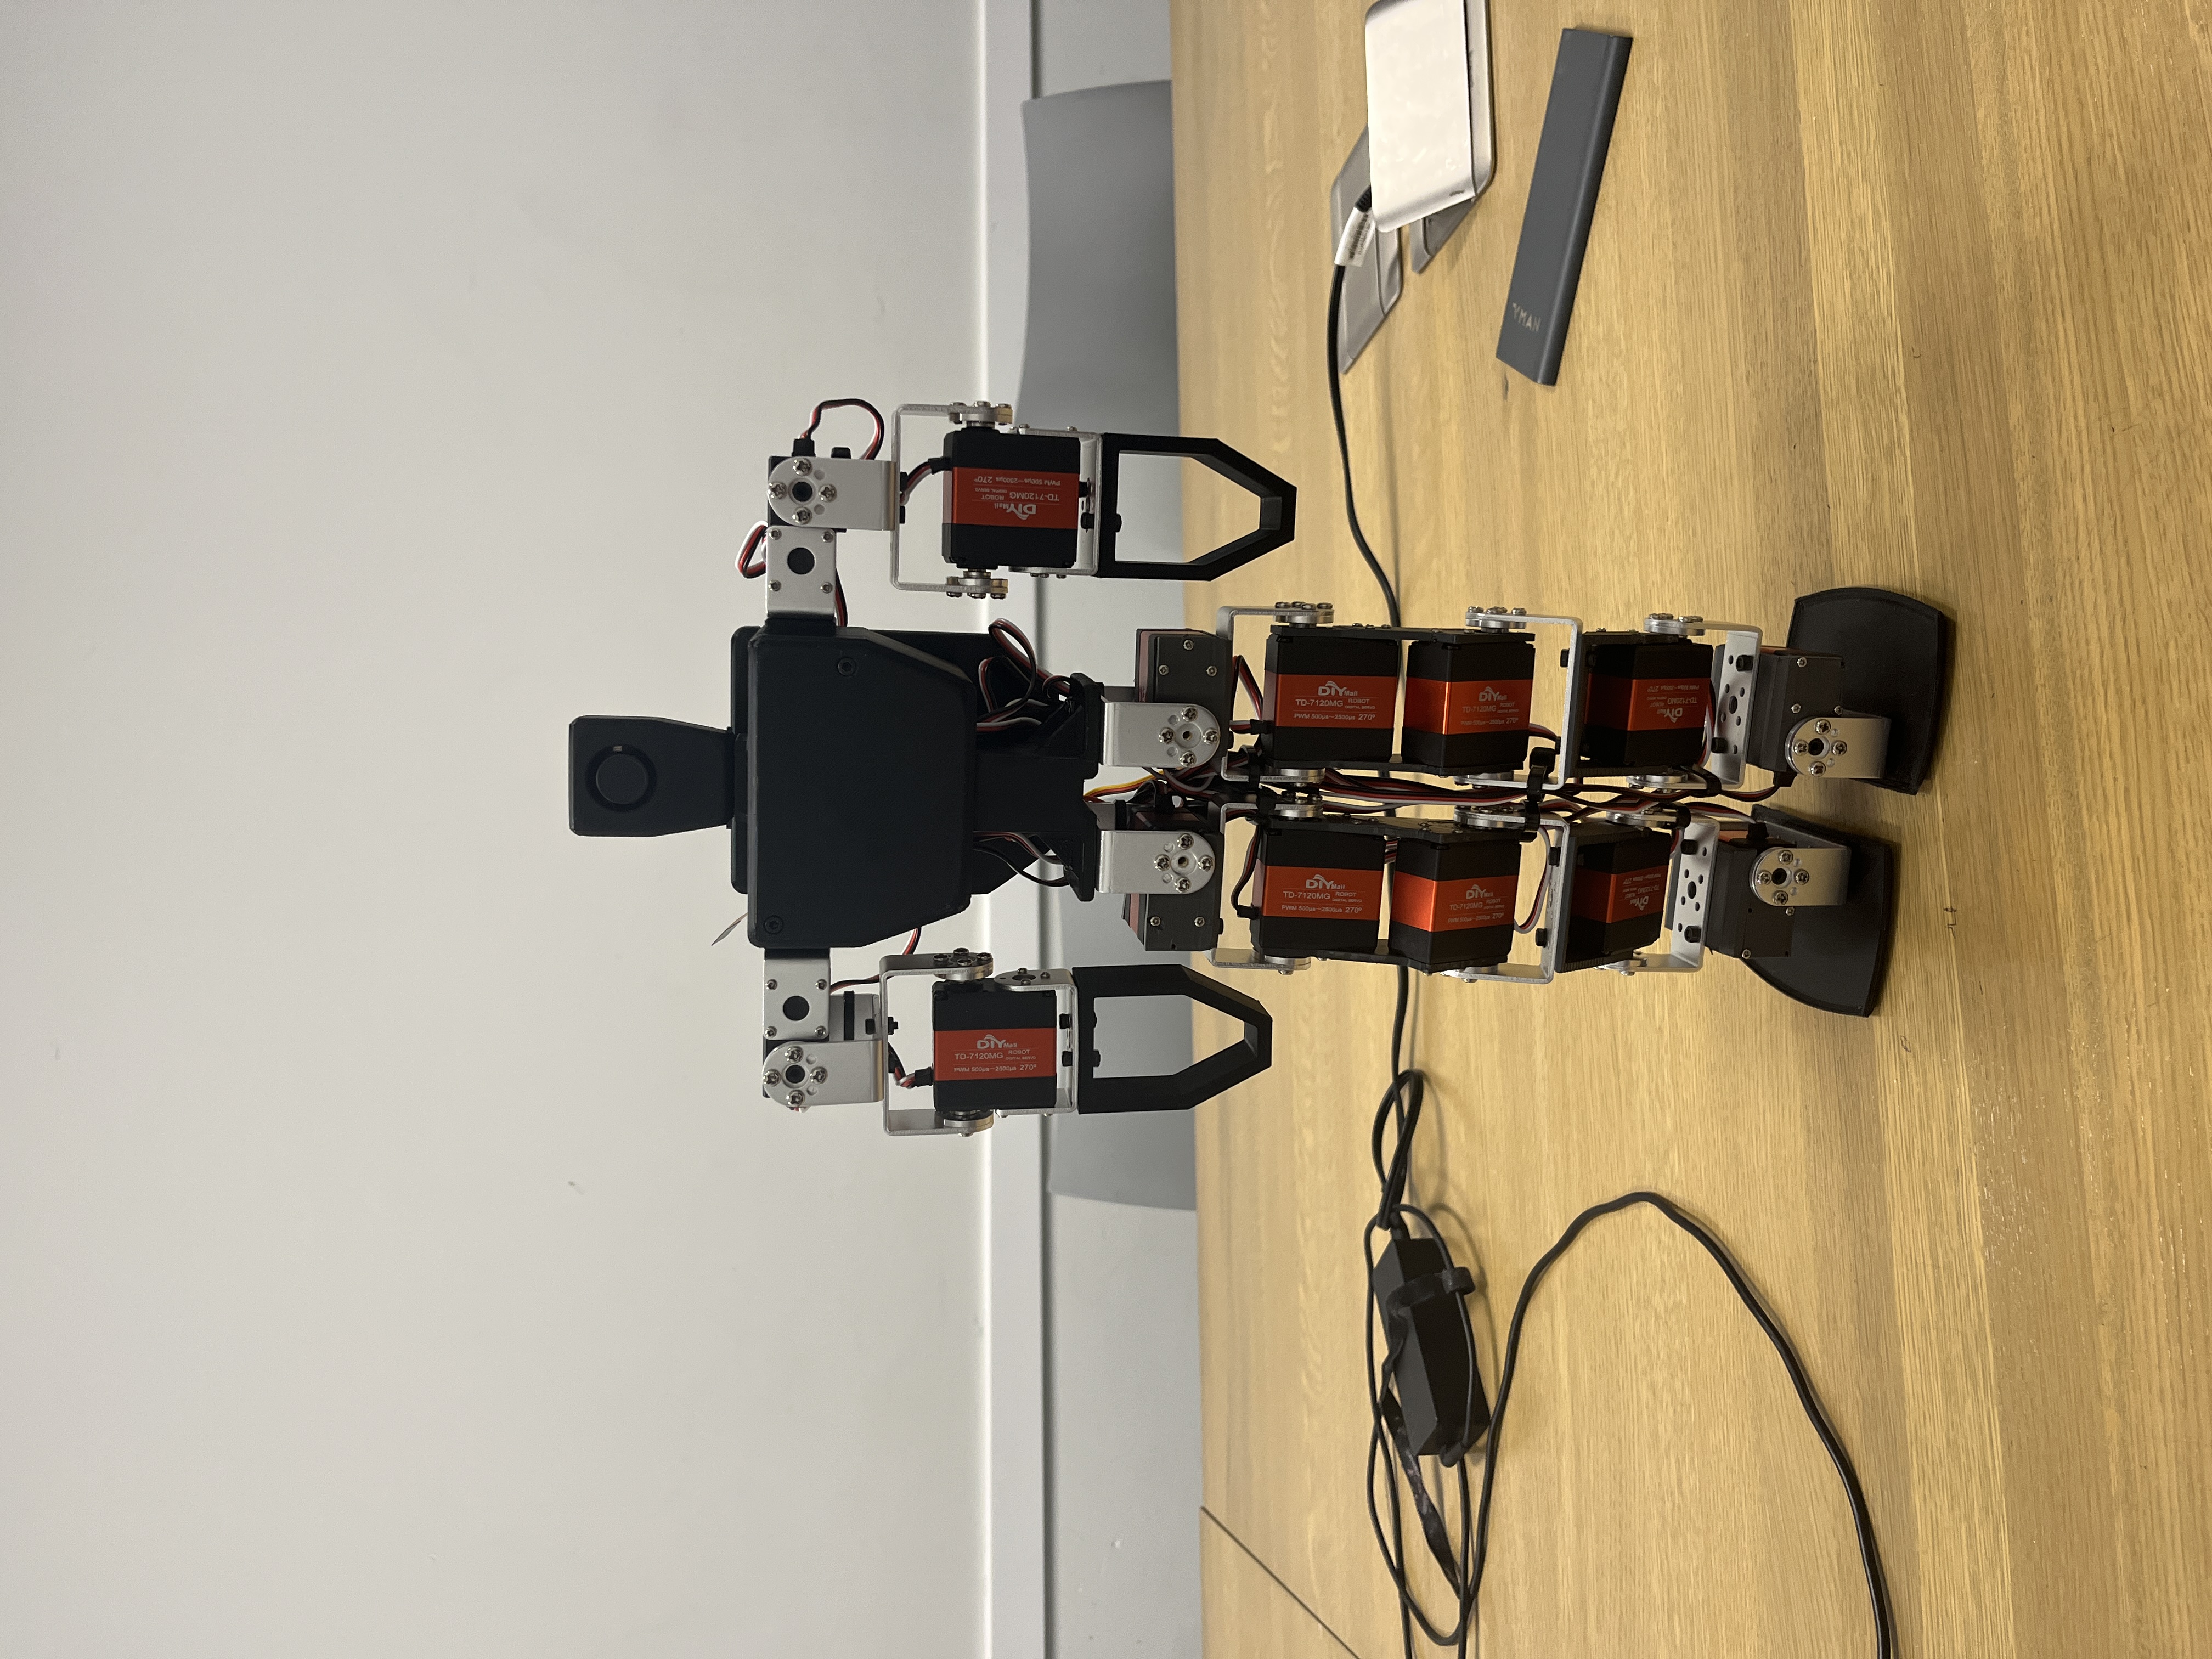
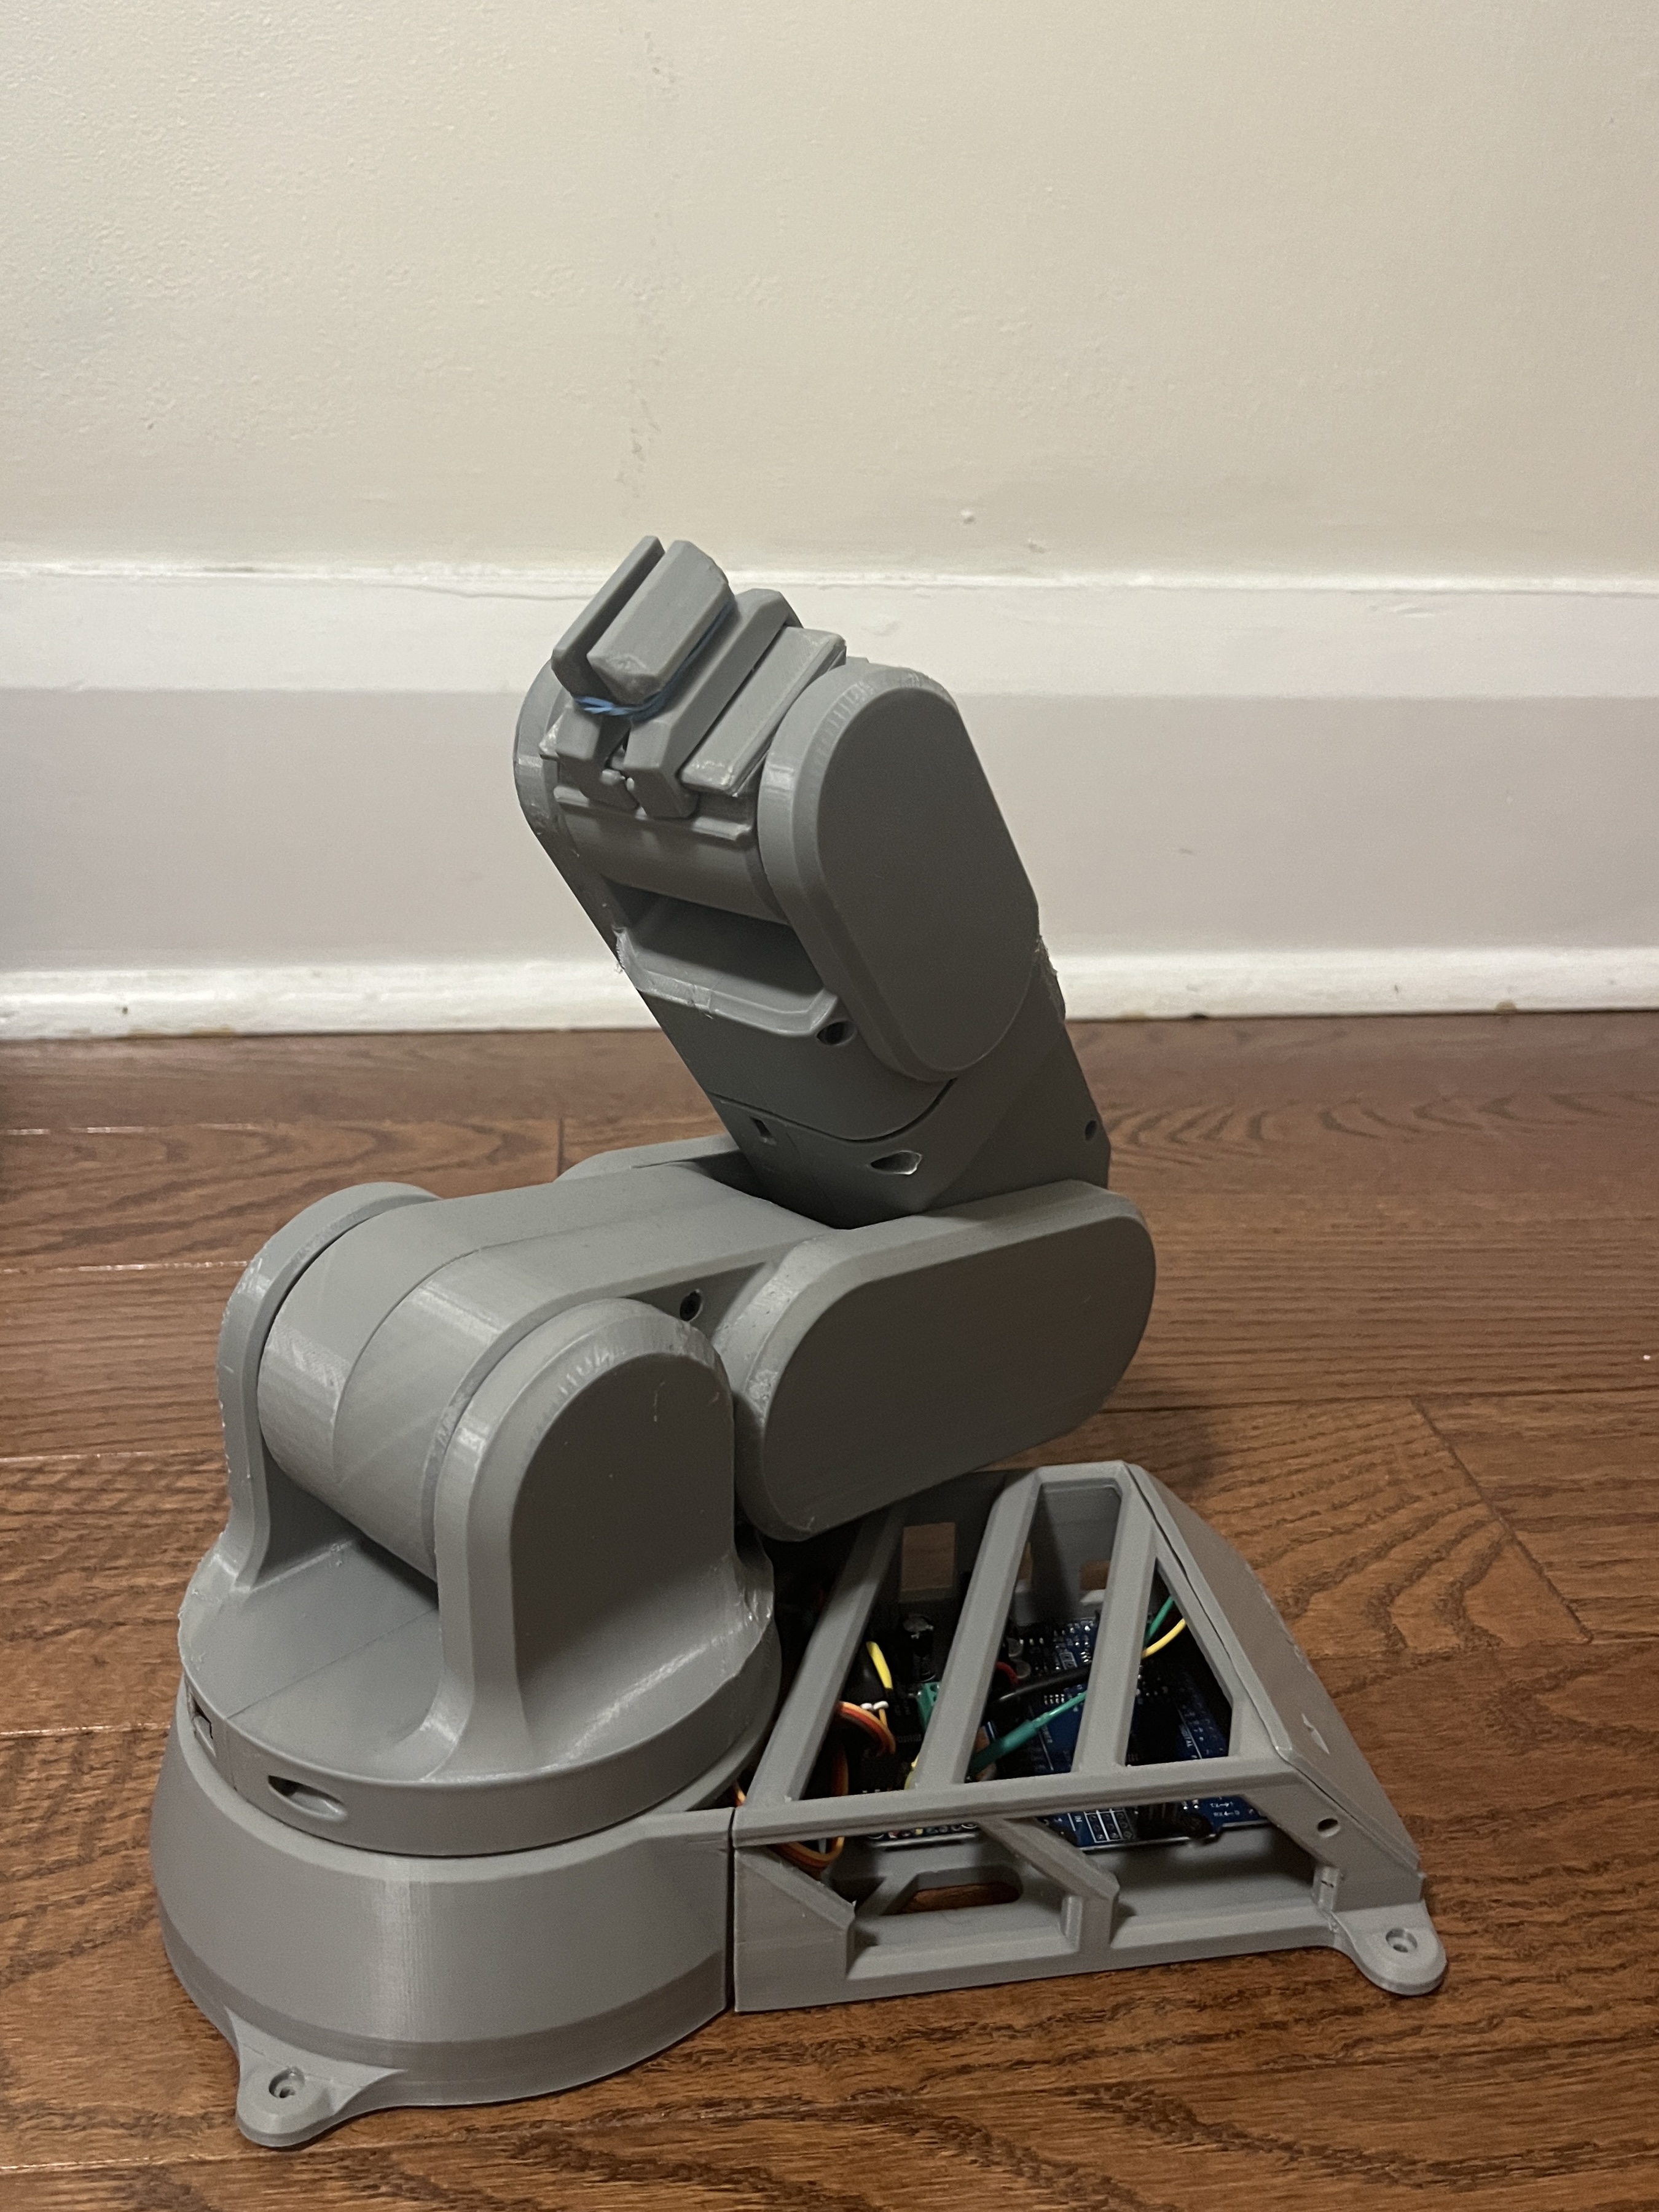
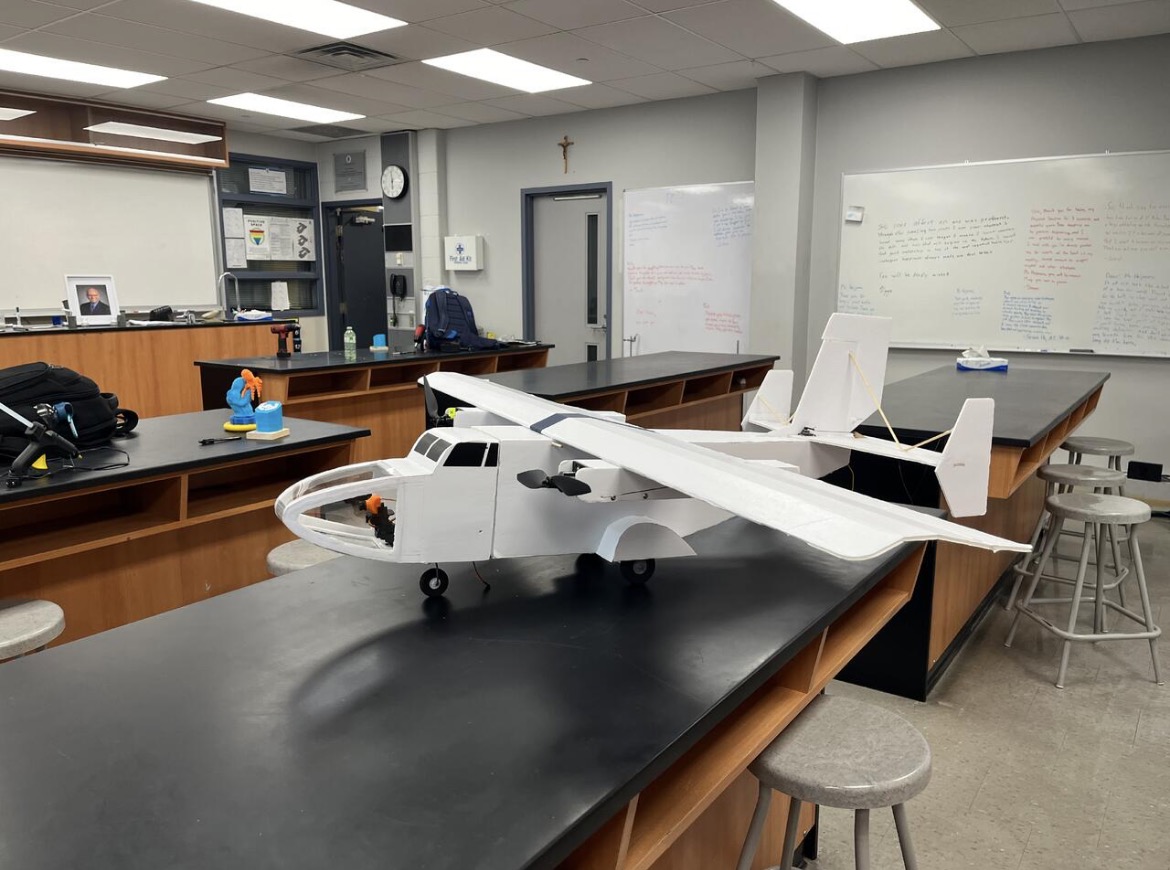
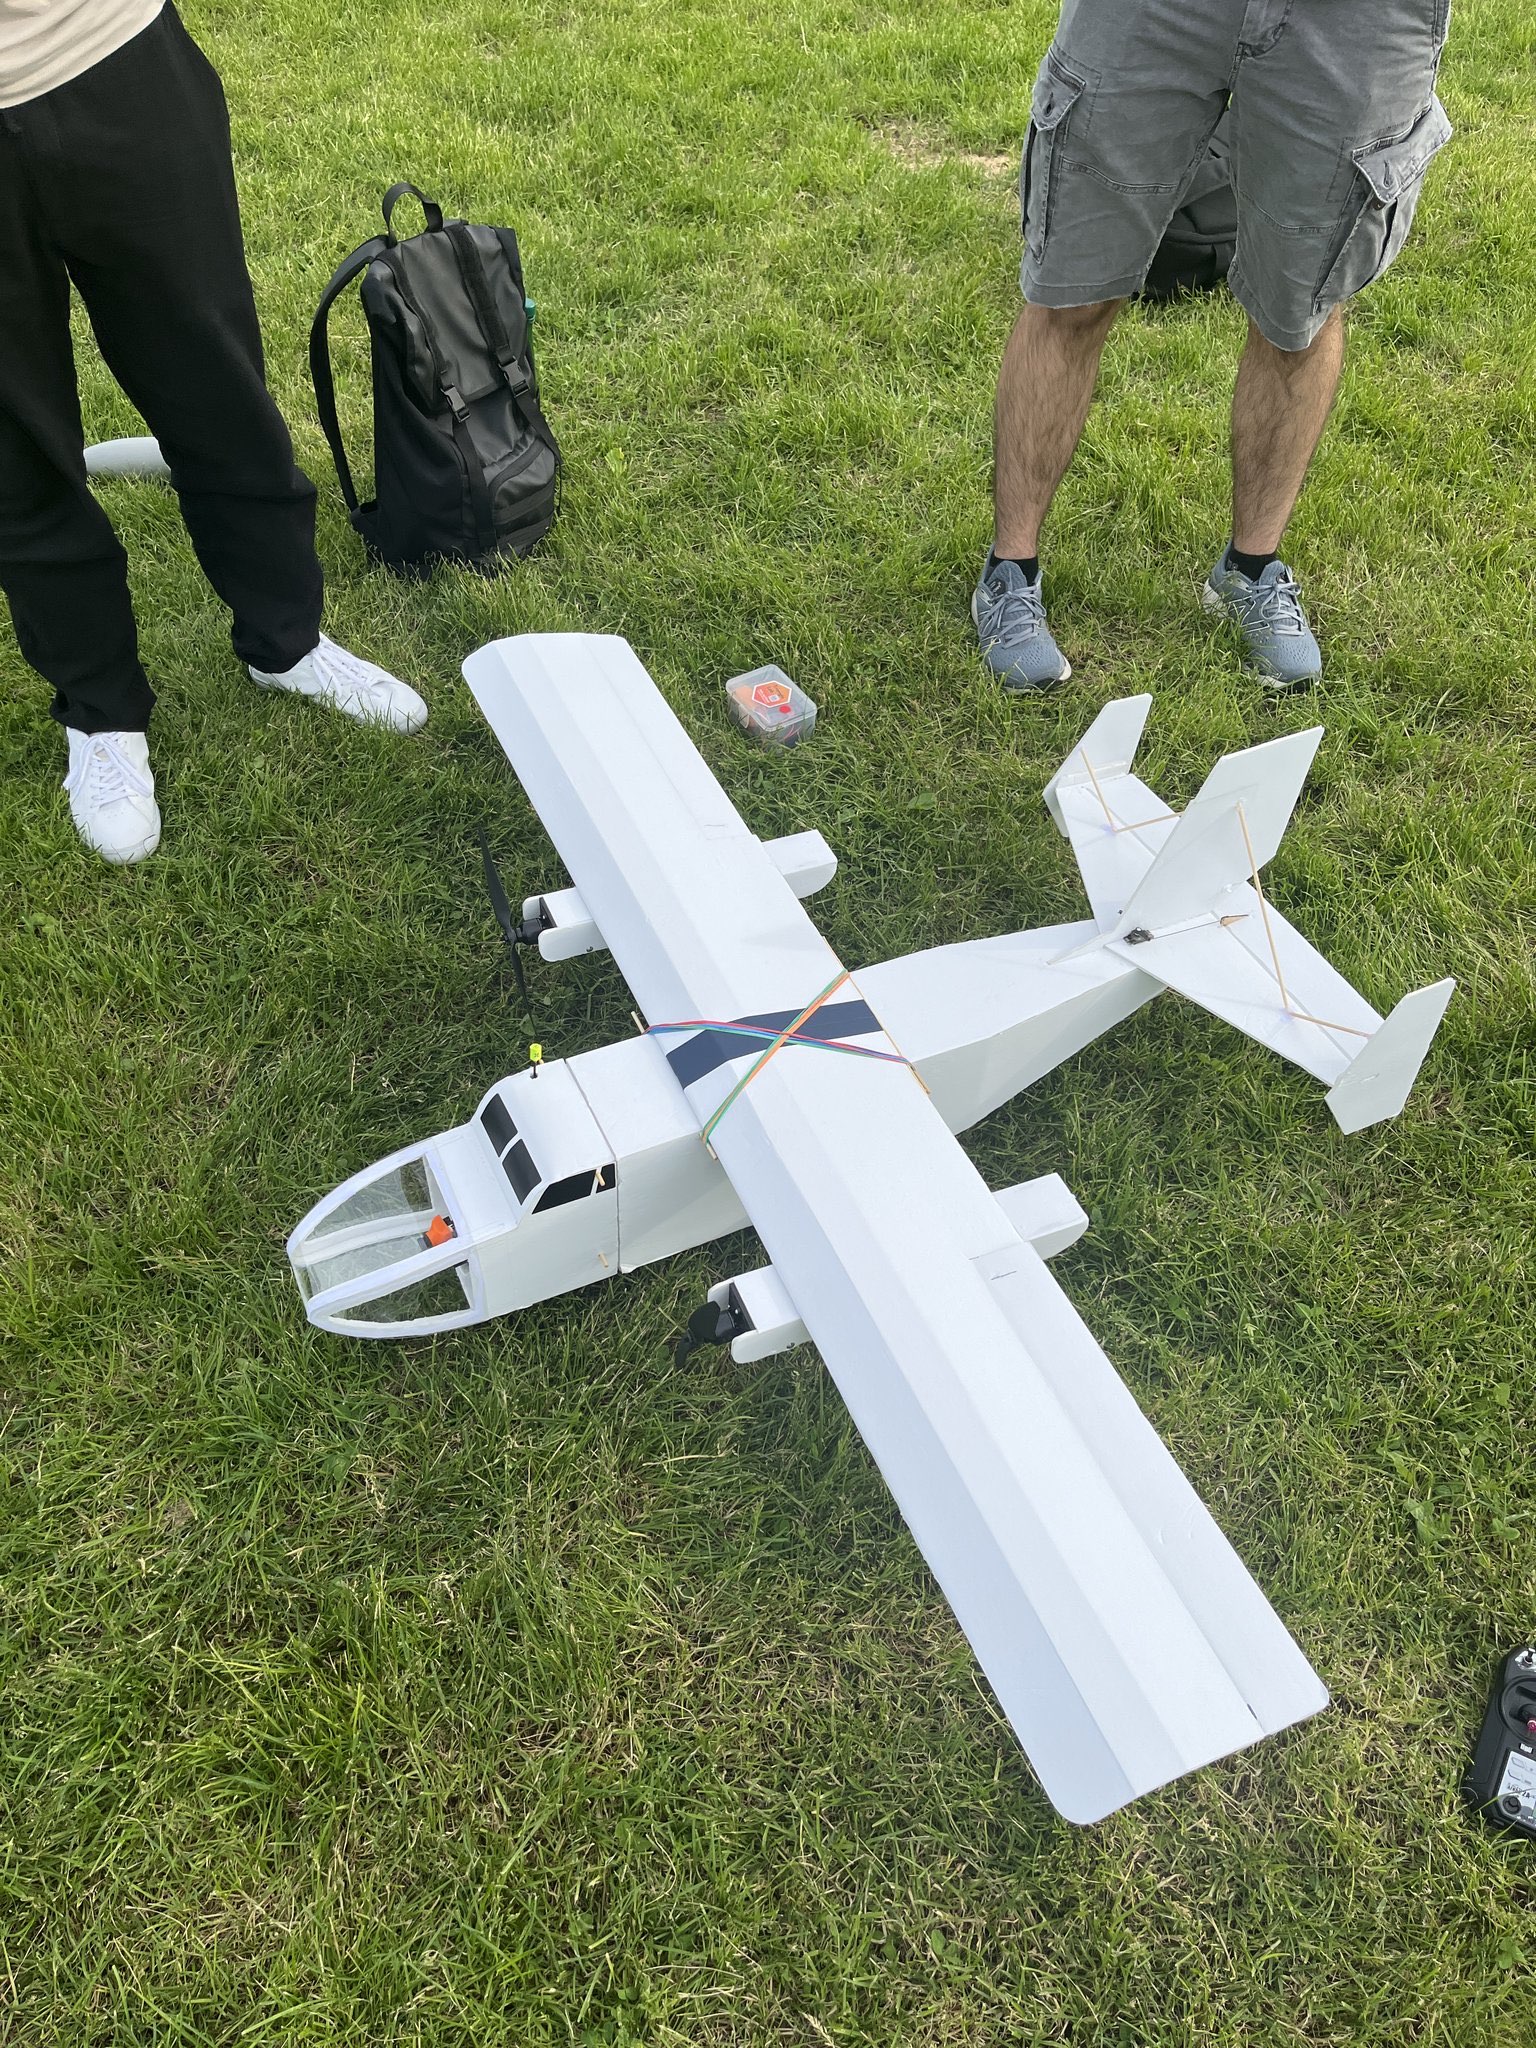
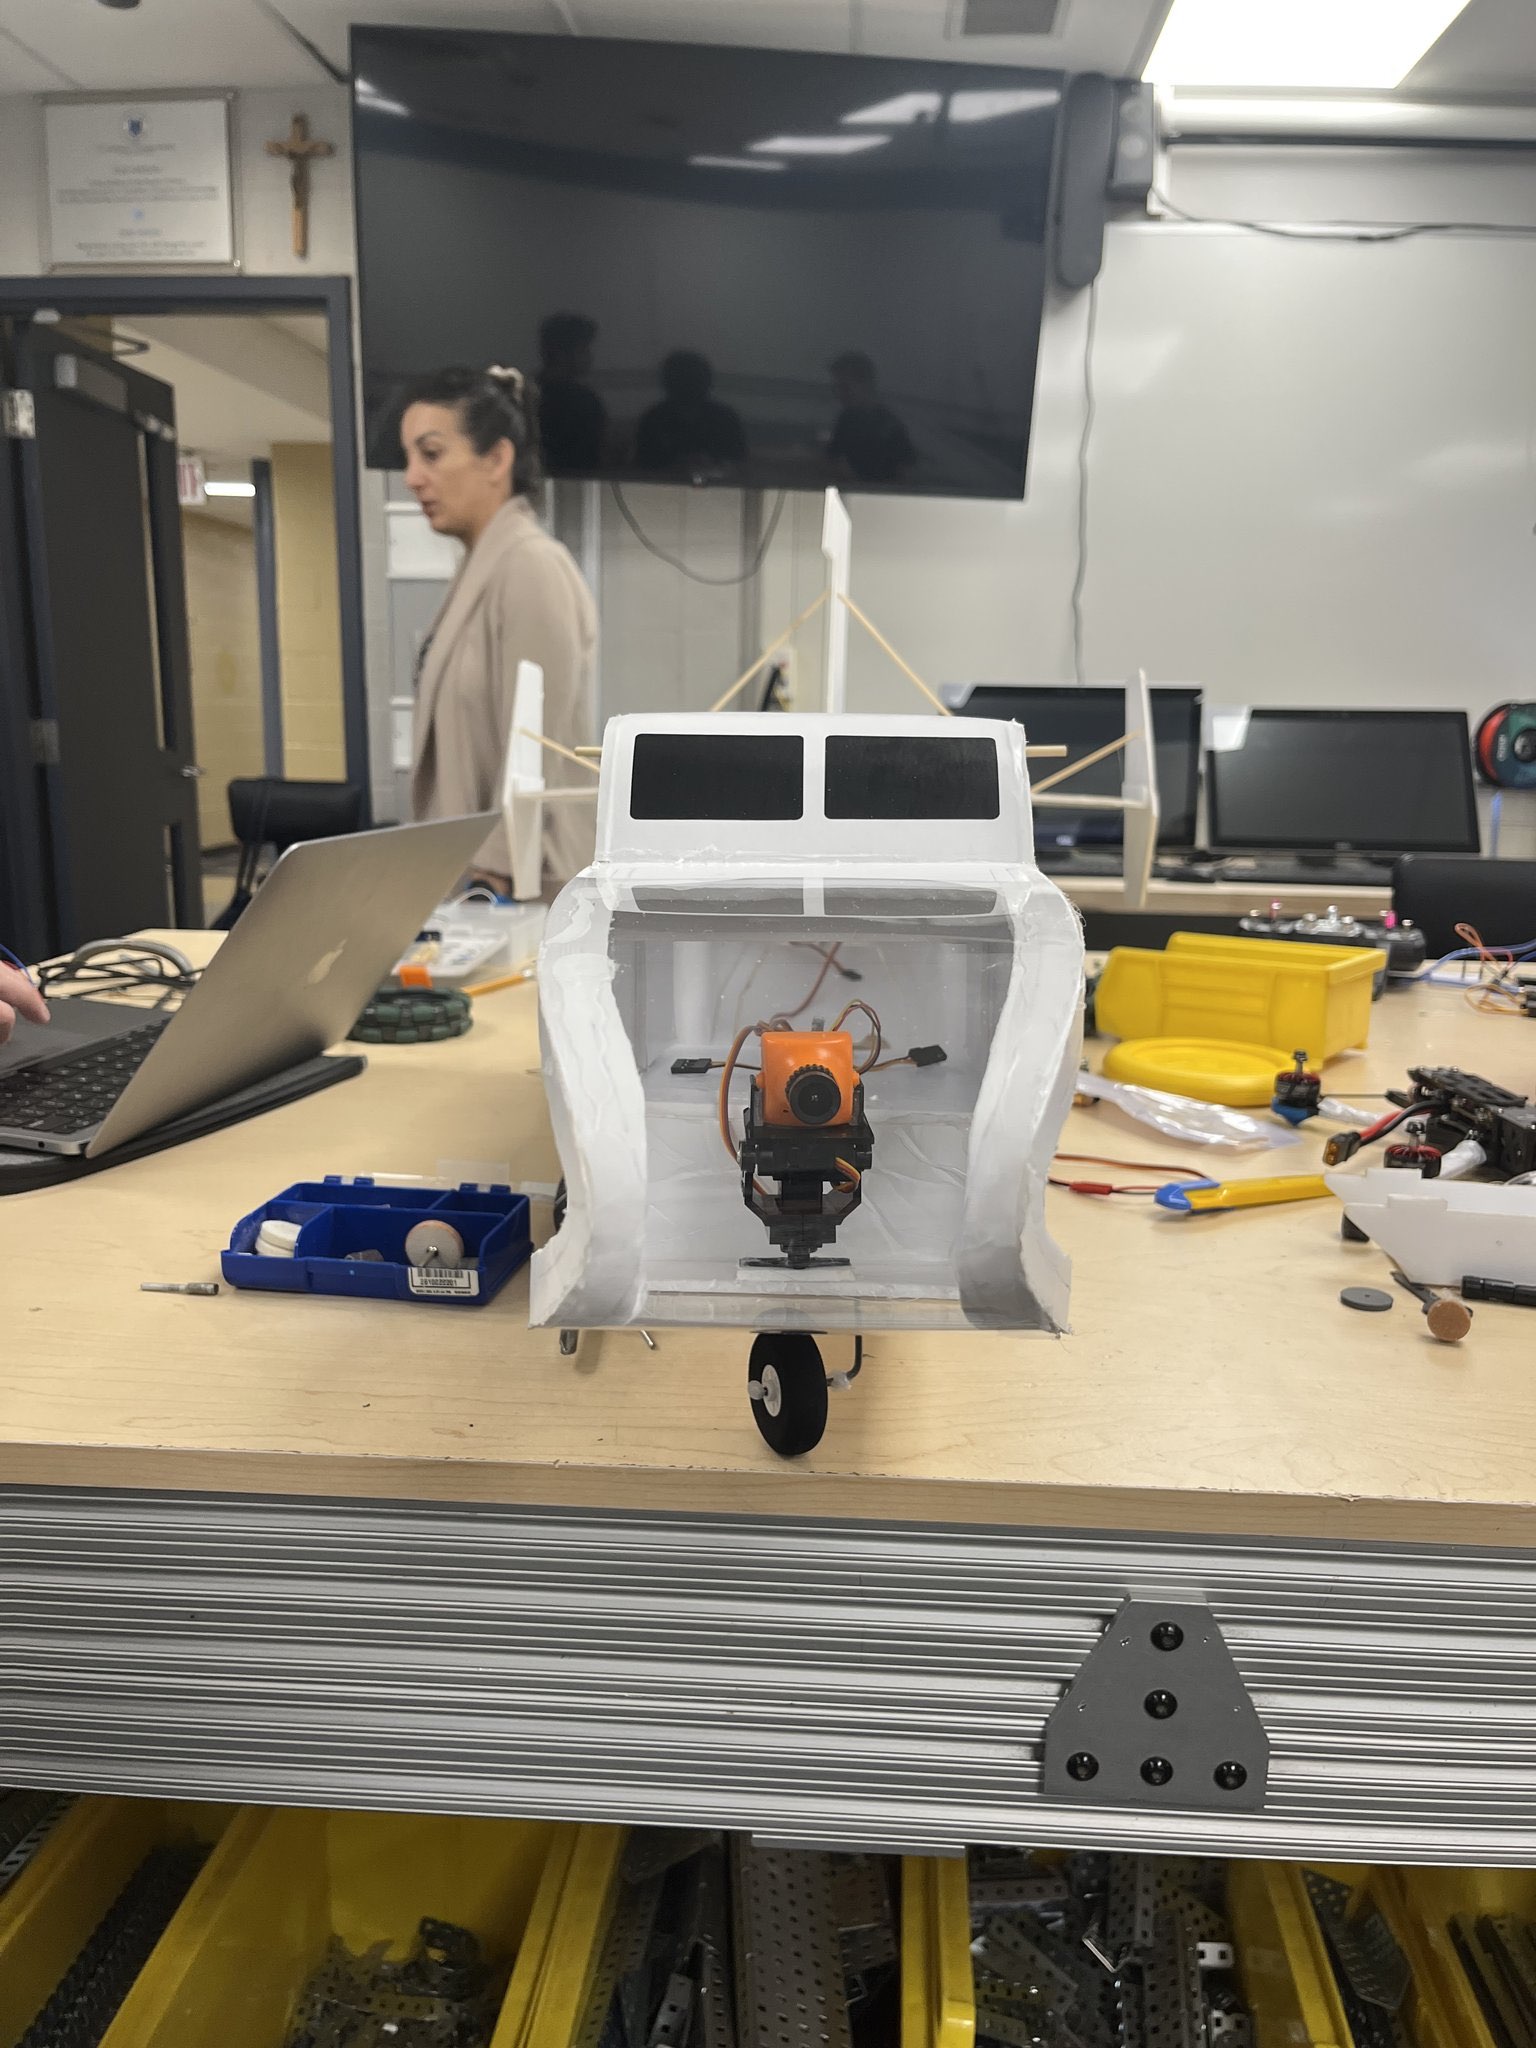
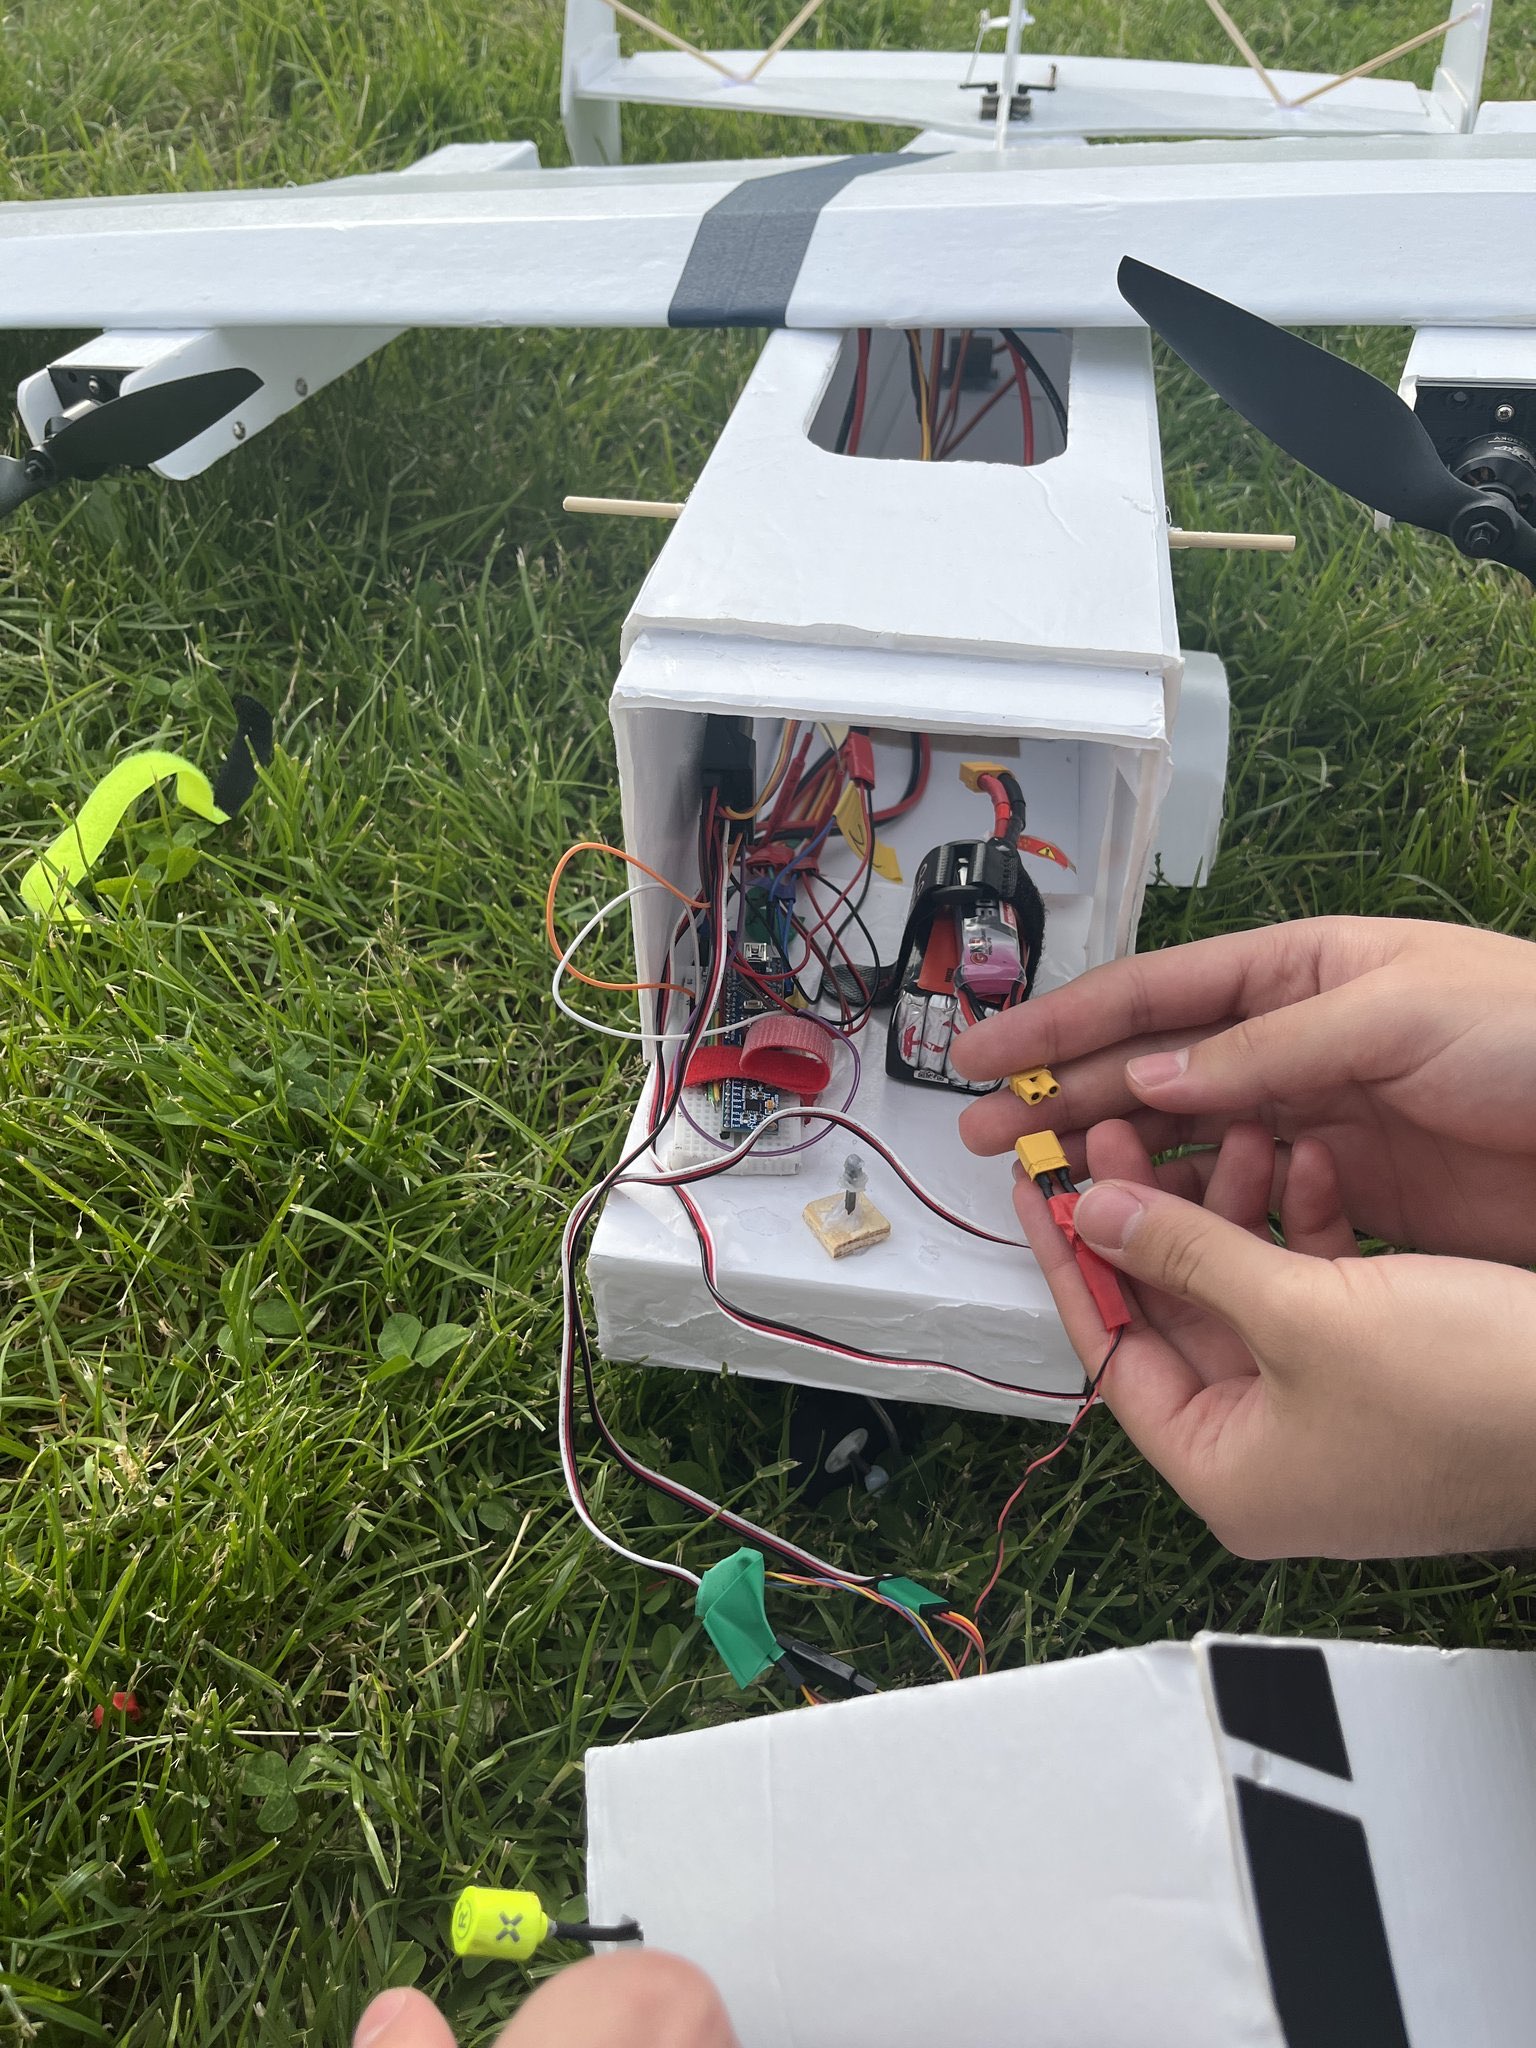
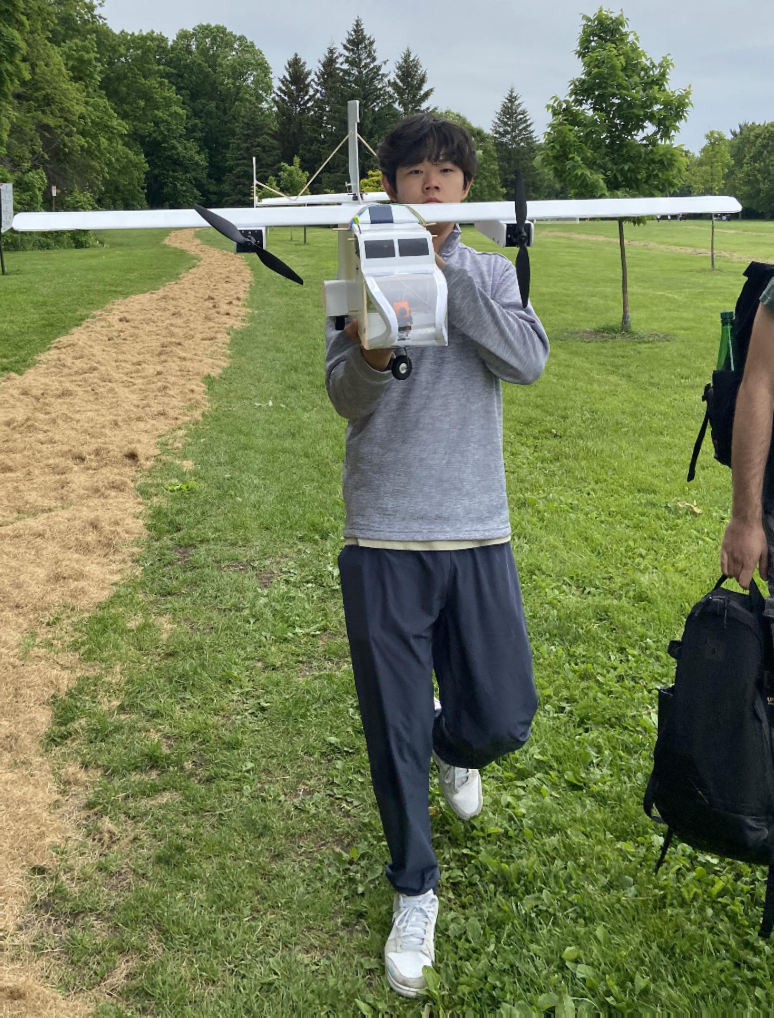
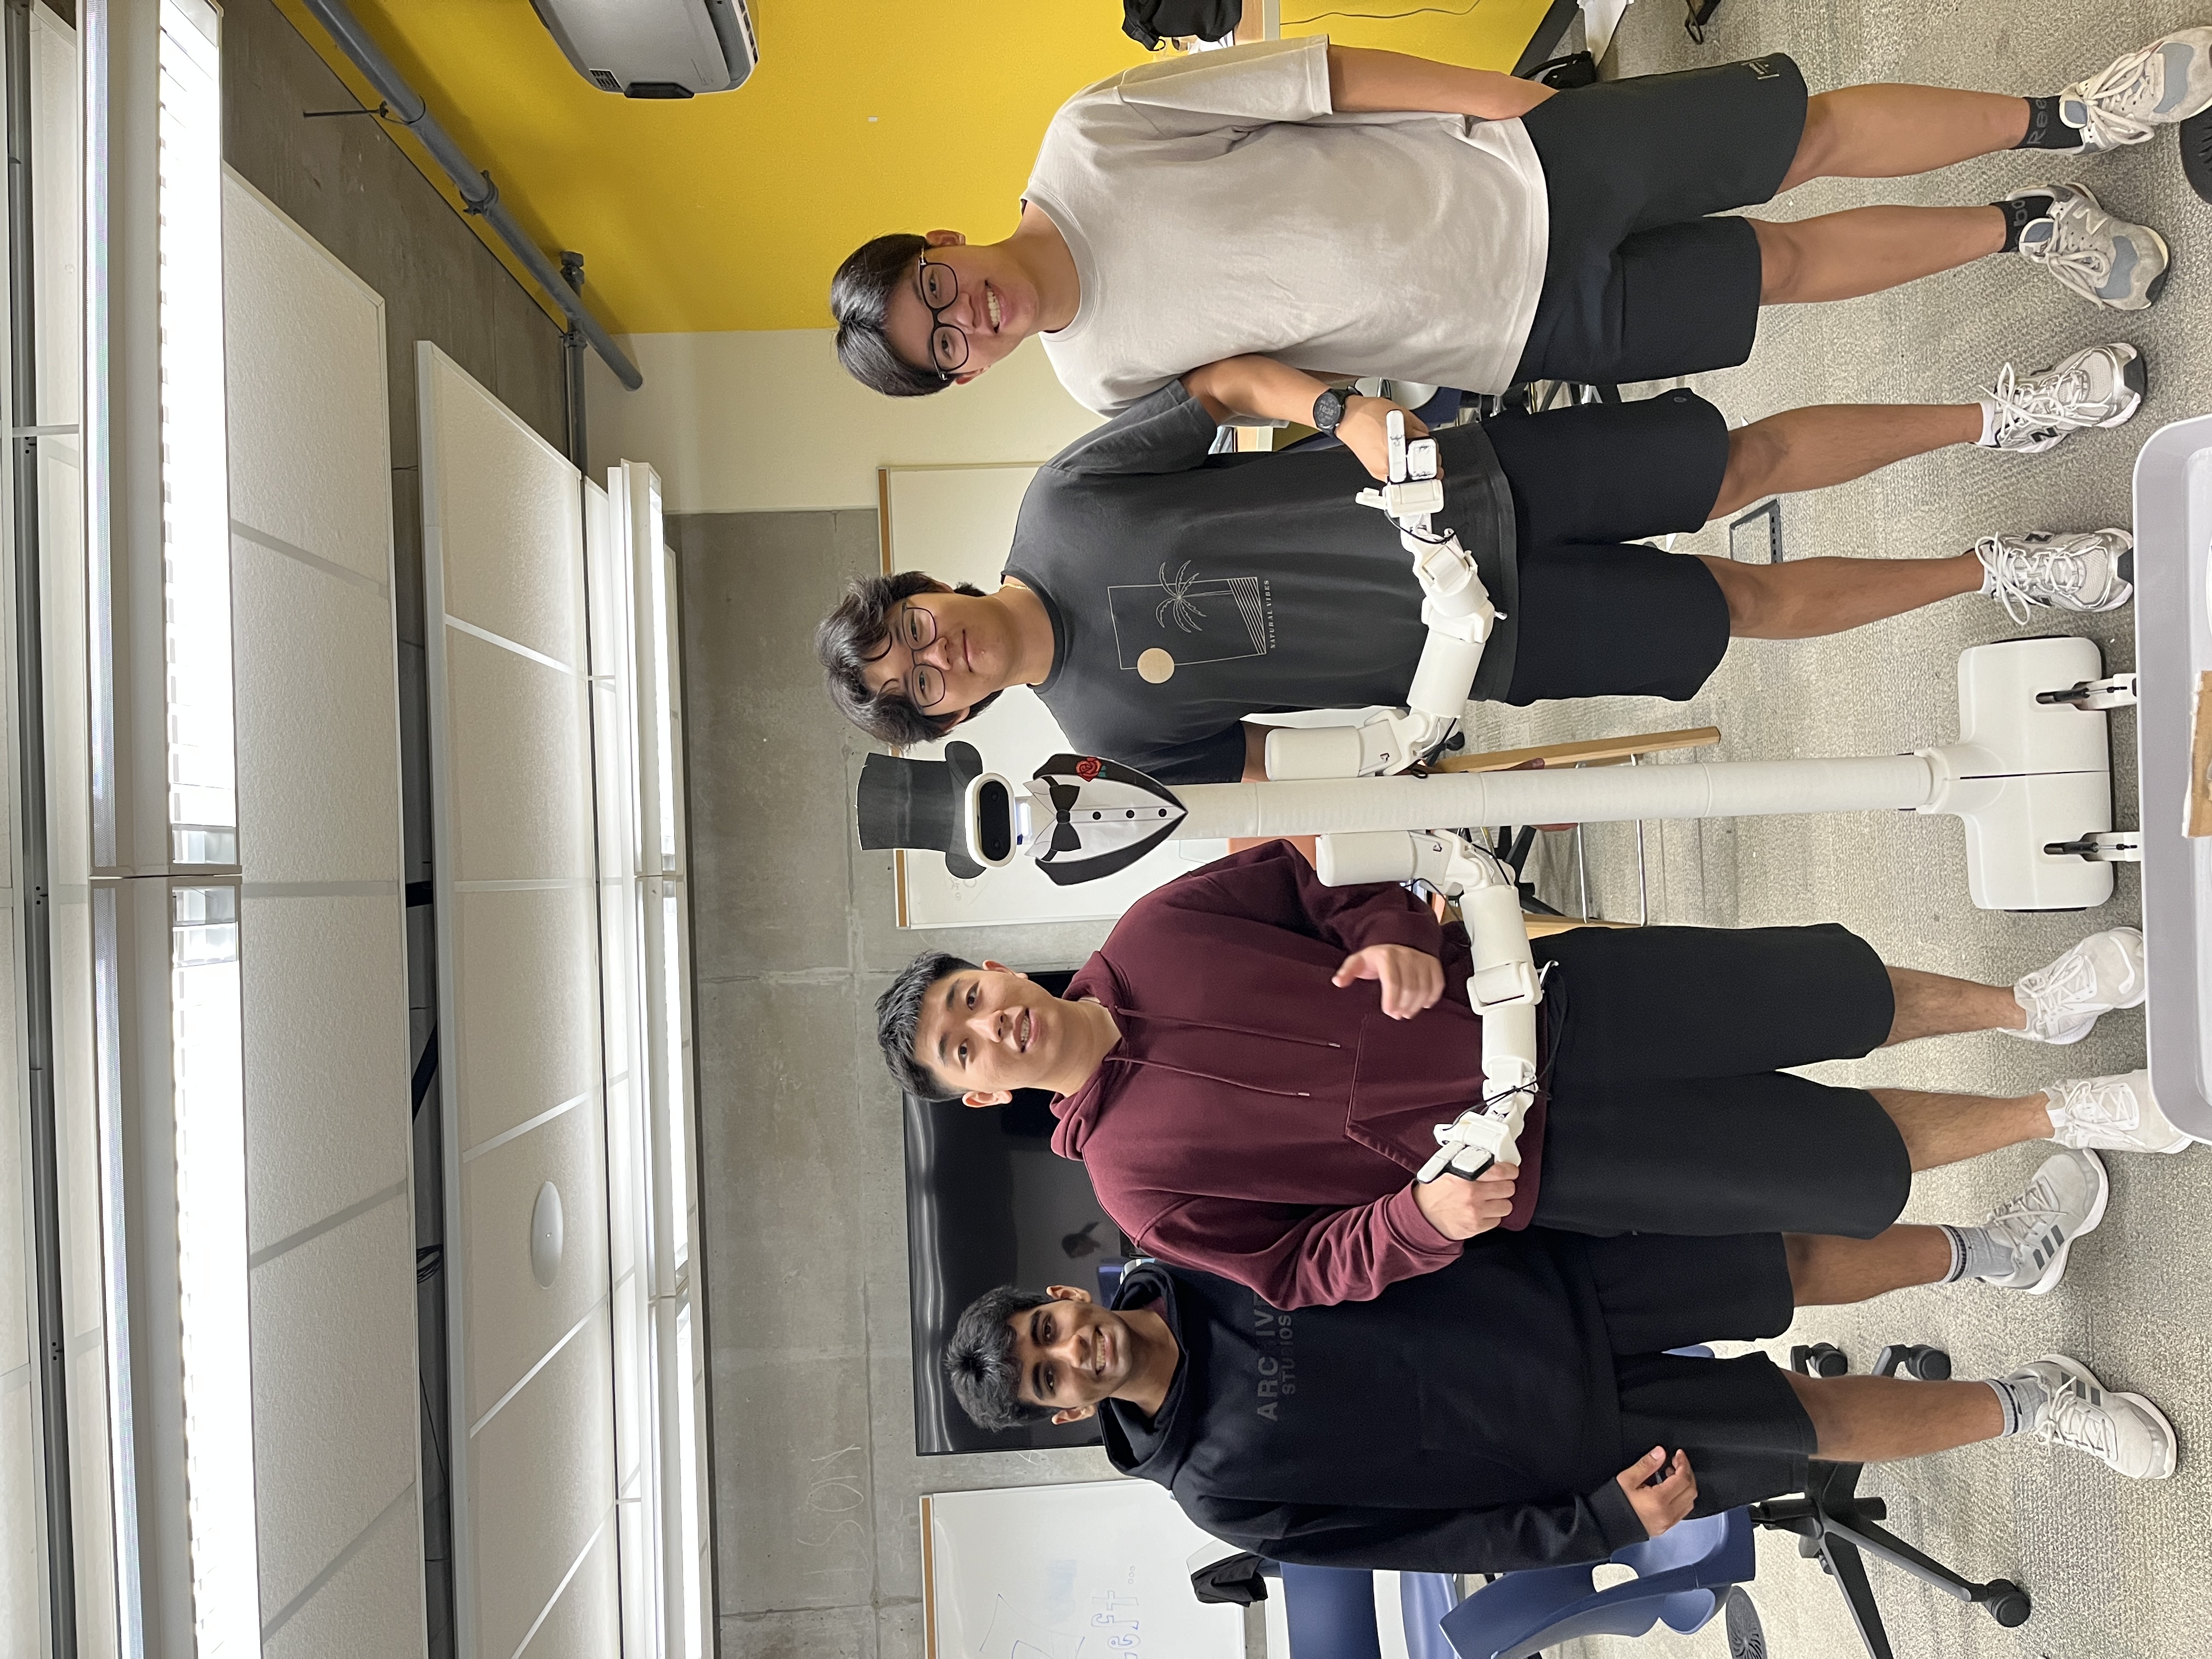
Personal robotics projects, each built end-to-end from mechanical design/assembly, simulation, and control.
Click a project to expand and learn more!

Where I've worked

Experience

UTFR Driverless Mapping and Electrical Team Member

Sep 2025 – Present

University of Toronto Formula Racing

  • Developed autonomous mapping and localization software using FastSLAM and ROS, integrating multi-sensor telemetry to improve high-speed state estimation on an autonomous racecar.
  • Diagnosed sensor orientation errors and built visualization tooling in Foxglove Studio to debug live and recorded vehicle telemetry.
  • Collaborated with a multidisciplinary robotics team via Git/GitHub to iterate on algorithm design and system architecture.
  • Joined the electrical team's Altium group, working on PCB design and power circuitry for the car's onboard systems, and contributing to the basic firmware architecture.

Biomedical Volunteer

Aug 2026 – Present

St. Michael's Hospital

  • Diagnosed and repaired electro-mechanical and sensor-level faults in clinical medical devices alongside hospital clinical engineering staff.
  • Executed preventive maintenance and electrical safety validation protocols, ensuring full regulatory compliance and minimal downtime.

Predictive Modeling Team

Aug 2024

AI Camp

  • Developed supervised machine learning models on large, real-world datasets, performing feature engineering, preprocessing, and model evaluation.
  • Analyzed model performance and limitations to guide iterative improvements.

VEX Robotics Club Moderator

High school

St. Michael's College School

  • Moderated the VEX Robotics club, mentoring 6 different teams across multiple years in robot design, building, and programming fundamentals.
  • Placed at the provincial VEX Robotics tournament.
  • Also moderated the Computer Science club.

Studying

Education

University of Toronto

Sep 2024 – Apr 2029

B.A.Sc in Engineering Science — Robotics Engineering Major, Artificial Intelligence Minor

PEY Co-op

St. Michael's College School

Sep 2020 – Jun 2024

High School Diploma — Graduated with a 98.3% average

Moderated the VEX Robotics club (mentored 6 teams; placed at provincials) and the Computer Science club · Outdoor camp leader and peer tutor

Toolbox

Skills

Robotics & Controls

ROS / ROS2SLAM (FastSLAM) PID ControlURDF & Kinematics NVIDIA Isaac SimMuJoCo Foxglove StudioEmbedded Systems FPGA / SystemVerilog

Computer Vision

OpenCVCamera Calibration Object Segmentation2D-to-3D Localization

Machine Learning & AI

PyTorchReinforcement Learning Stable Baselines3Feature Engineering Generative AI / LLMs

Programming

PythonC / C++ JavaData Structures & Algorithms Git / GitHubLinux / Bash

Systems & Hardware

Raspberry PiArduino PWM / Servos / SteppersI2C / SPI / UART Altium DesignerPCB Design

Mechanical Prototyping

Fusion 360AutoCAD MATLABFDM 3D Printing

How I work

  • Strong technical and problem-solving skills
  • Excellent communication and collaboration skills
  • Ability to work independently and navigate ambiguous engineering problems
  • Strong attention to quality and technical detail
  • Ability to contribute effectively in a multi-site, cross-functional team

Contact

Looking for a co-op student for Fall/Winter 2027? I'd love to hear from you.